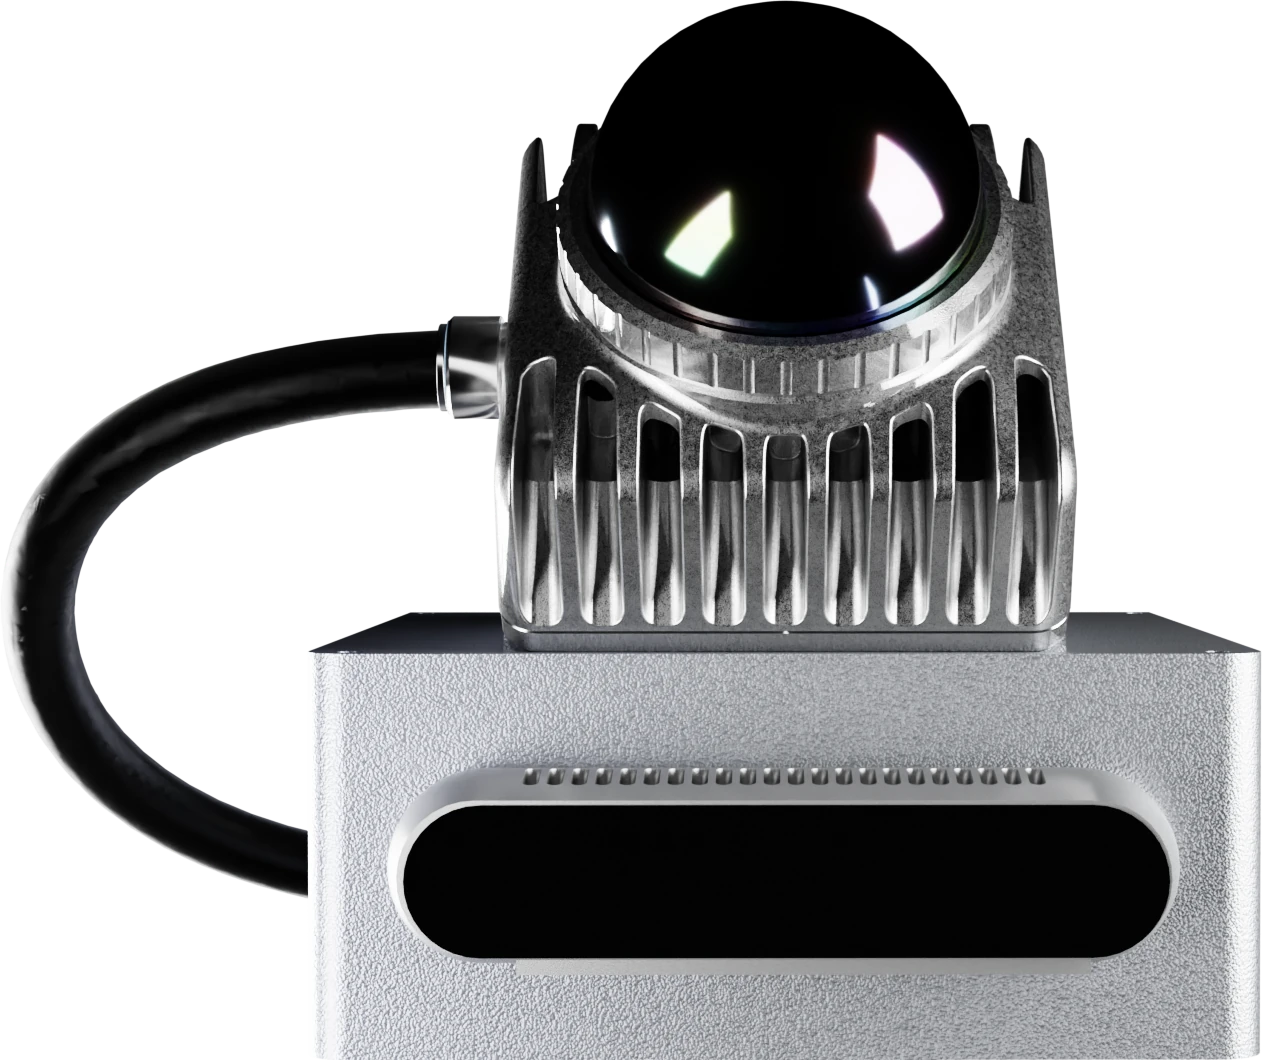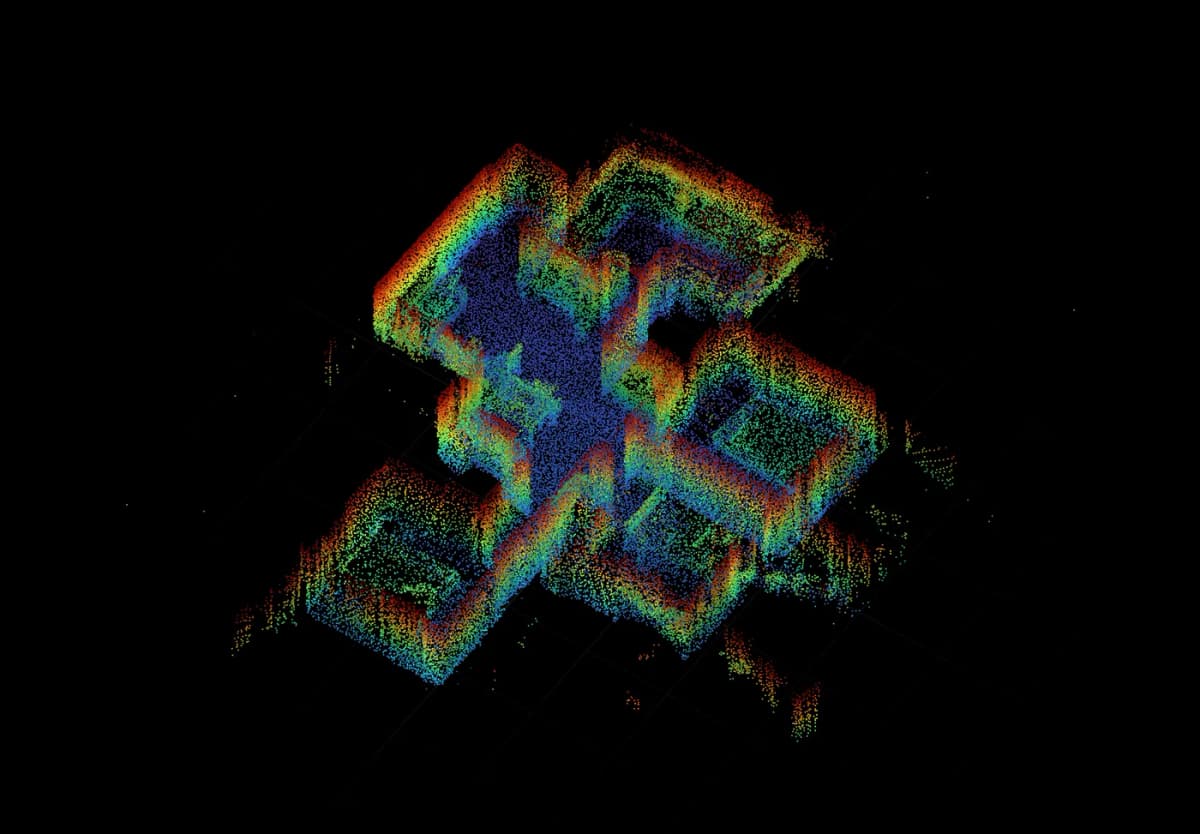
ATLAS by Robolabs AI, a mobile mapping system

Real-time 3D mapping from one sensor head: on foot, in the air or on a vehicle.

Book a demo

Recorded with Atlas · 27 Sept 2026

The map buildswith every step.

One handheld walk through an apartment, registered on the head in real time. Gaps in coverage show up on site, while you can still go back for them.

Walked
0.0m
Points
0
Floor to ceiling
2.65m
Accuracy
±30mm

One head.Every carrier.

One sensor head for every carrier
  1. Handheld

    Carried on its battery grip. Walk a site and the map grows with every step.

  2. Aerial

    Release the grip and the same head mounts inverted under a drone, mapping the site line by line.

  3. Vehicle and robot

    On a robot or vehicle it maps the space and locates the machine within it, at the same time.

Applications

Built for thesites you map.

Building interiors, open sites and infrastructure corridors. One instrument, the same data, whatever carries it.

Forestry: a site Atlas can map

Forestry

Stem maps, diameter and height for every tree in a plot.
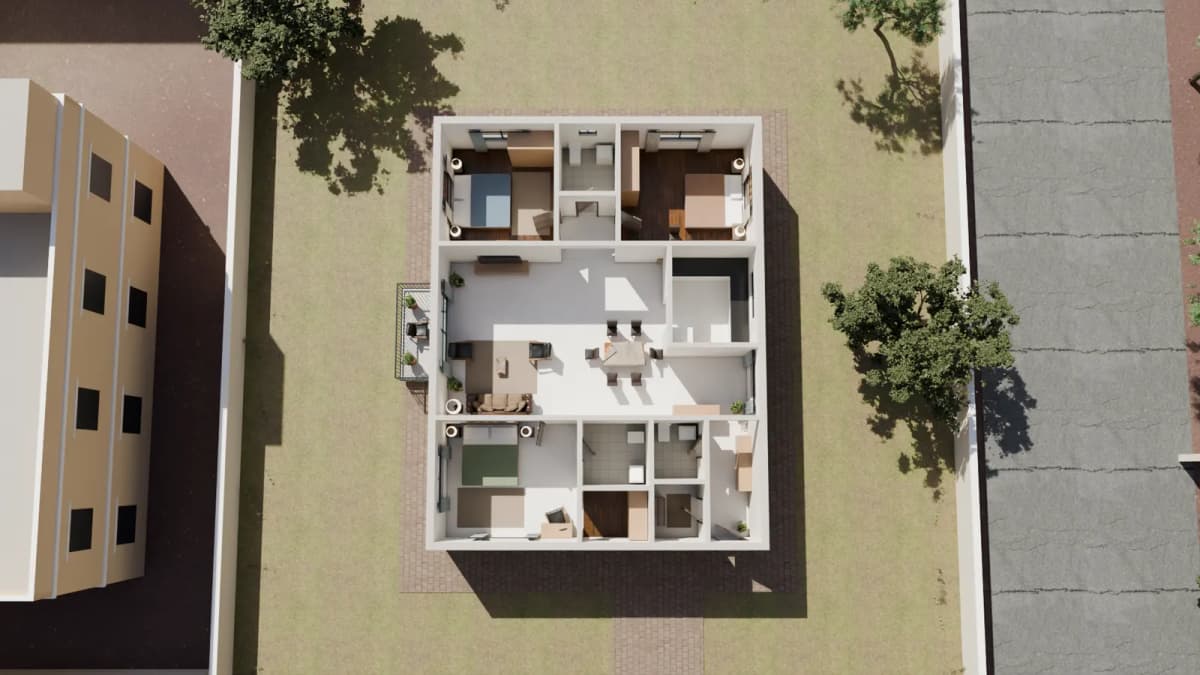
Real estate: a site Atlas can map

Real estate

Floor plans and scan-to-BIM from a single walk.
Industrial plants: a site Atlas can map

Industrial plants

Sections, profiles and clearances across pipe racks.
Tunnels and mining: a site Atlas can map

Tunnels and mining

Maps underground, where GPS can’t reach.
Agriculture: a site Atlas can map

Agriculture

Surveys fields from the air, row by row.
Infrastructure: a site Atlas can map

Infrastructure

Bridges and corridors, on foot or by drone.

Specifications

Field numbers,measured.

Atlas specifications

±30mm

Map accuracy over long runs

200,000pts/s

LiDAR capture rate

70m

LiDAR range

67TOPS

Processing on the head

715g

Sensor head weight

74Wh

Battery in the grip

Performance

Accuracy
±30 mm
Speed
200,000 points/s · 10 Hz scan rate
Output
.las / .laz, .e57, .ply, .pcd, trajectory
Modes
Handheld, aerial, vehicle and robot; real-time localization in saved maps

Sensors

LiDAR
360° × 59° FOV (−7° to +52°), 0.1–70 m (40 m at 10% reflectivity), ≤2 cm precision, mounted at 45°, 905 nm Class 1 eye-safe
Depth camera
Active stereo, global shutter; depth 1280 × 720 at 30 fps, 0.1–10 m, 87° × 58°; RGB 1920 × 1080 at 30 fps
IMU
Two 6-axis MEMS IMUs (LiDAR and camera)

Processing

Processor
GPU processing unit, 67 TOPS; 1,024-core GPU, 32 Tensor Cores; 6-core Arm CPU; 8 GB LPDDR5
OS / storage
Ubuntu 22.04 LTS; 256 GB NVMe SSD (upgradable)
Connectivity
Wi‑Fi live map in any browser; Gigabit Ethernet; USB 3.2

Power and physical

Power
15–35 W system draw (mode dependent)
Battery
20,000 mAh Li-ion (74 Wh) in the grip
Battery life
1 h 50 min LiDAR + camera · 2 h 55 min LiDAR only · 12 h standby
Weight
715 g sensor head (grip not included)
Operating temperature
0 °C to 35 °C
Mounting
Handheld grip, UAV (head inverted), ground robot, vehicle, ATV; universal quick-mount
GNSS
Optional RTK GNSS receiver and bracket
Warranty
1 year hardware (2-year extension available), 1 year software service

Atlas by Robolabs AI

An atlas used to bea book of maps.This one makes them.

Book an Atlas demo
Book a demo
[email protected]
Atlas sensor head, front view